Human-Robot Interaction
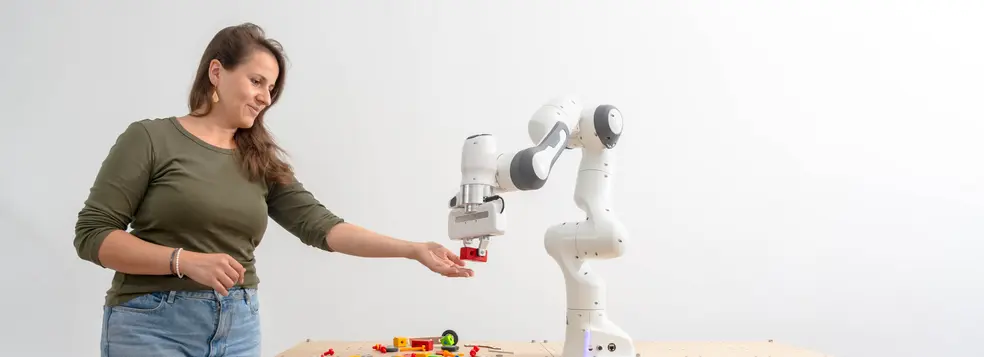
Shared Understanding and Joint Action
When humans and robots work together, they need to communicate and coordinate their actions. Speech, gestures, gaze and movement derive their meaning from the shared situation. A central question is how robotic systems can interpret human input and behavior while making their own actions understandable.
Shared tasks combine communication with spatial and temporal coordination. Expectations may differ, and input may be ambiguous. How can misunderstandings be detected and resolved? How can a robot’s behavior help people anticipate its next actions and adjust their own actions accordingly?
Technical experiments and user studies guide the development of interaction methods in our group. We examine how people experience the interaction and how the design of robot behavior affects the way people and robots carry out tasks together.
Selected Research Projects
JAMES: Joint Action for Multimodal Embodied Social Systems
EU FP7 · 2011–2014
Multimodal interaction with multiple participants, task and motion planning, and evaluation of different interaction approaches.
BAJA: Basic Aspects of Joint Action
DFG EXC CoTeSys · 2009–2010
Multimodal signals, object handovers, and the effects of different motion profiles in human-robot interaction.
JAHIR: Joint Action for Humans and Industrial Robots
DFG EXC CoTeSys · 2006–2009
Nonverbal communication, dialog-based assembly, and physical collaboration with industrial robots in shared workspaces.
JAST: Joint-Action Science and Technology
EU FP6 · 2004–2008
Multimodal interaction in a shared assembly task, combining dialog, goal inference, task planning, and physical execution.